Back to Projects
ASK project

ASK

Robot Make
Kawasaki
Software
Process Simulate
Total Robots
1
Application
Machine Tending, Material Handling
End Customers
ASK

The Customer

A precision component manufacturer running multiple CNC operations in sequence

The customer runs a CNC machining setup where a single component moves through three separate machining operations before it is finished. Team Torque was brought in to automate the material flow between these stations and remove manual handling from the process.

The Problem

Manual loading and unloading across three CNC machines was slowing the line down

The part had to be manually picked from the first CNC machine, transferred to the second, and finally moved to the third before the cycle was complete. This manual transfer between three separate machines led to inconsistent cycle times, operator dependency, and idle machine time while parts were being handled by hand.

Approach Taken

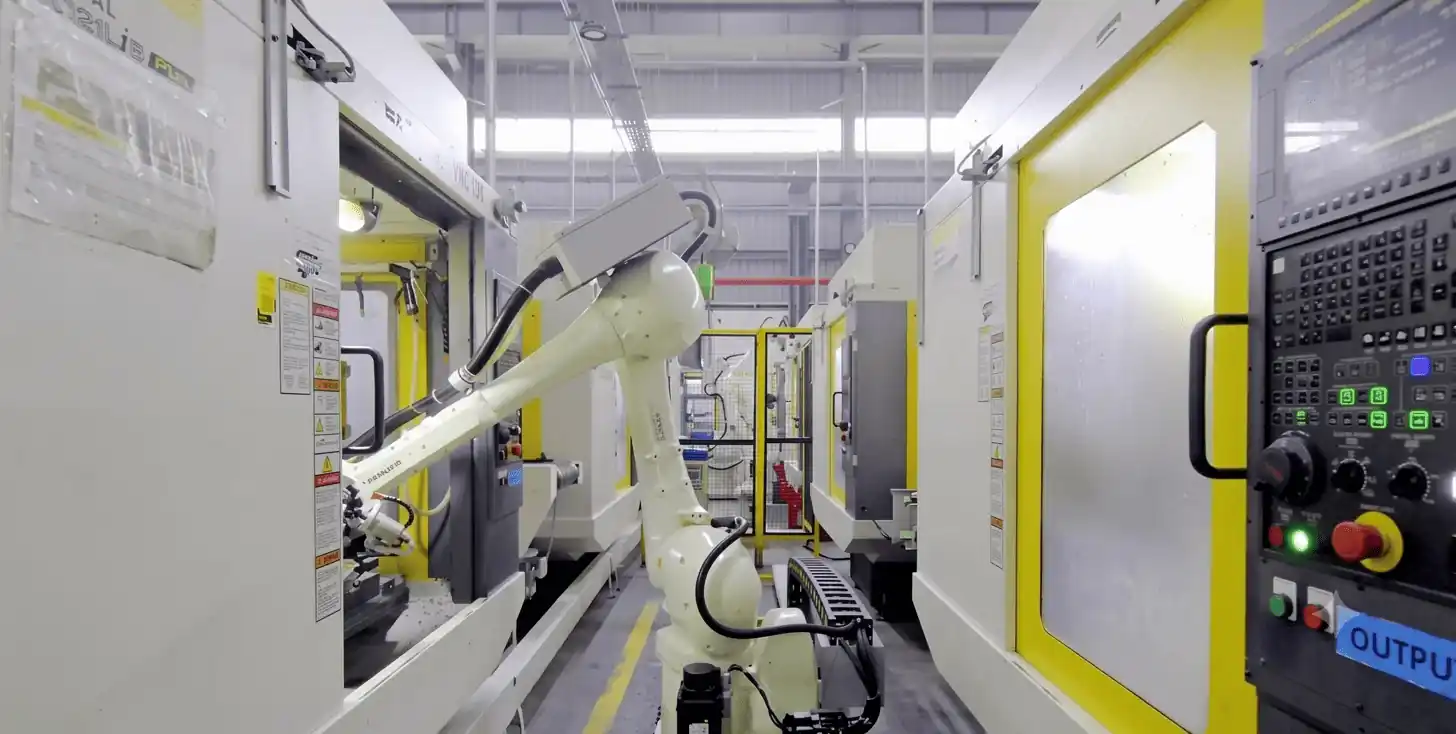
A single robot on a linear track to tend all three machines

Instead of deploying a robot at each machine, Torque designed a machine tending cell around one robot mounted on a linear track. The robot picks the part from the first CNC machine, places it in the second for the next operation, then picks it up again and loads it into the third machine to complete the sequence. The linear track gives the single robot enough reach to service all three machines, keeping the footprint and cost of the cell to a minimum while synchronizing pick and place timing with each machine's cycle.

Results Achieved

Fully automated part transfer across all three CNC operations

The cell now runs unattended, with the robot handling every pick and place move between the three machines. This removed manual intervention from the process, improved cycle time consistency, and let the customer run the three-machine sequence with a single robot instead of dedicating a machine tending unit to each station.

Contact Us